#include <body.h>
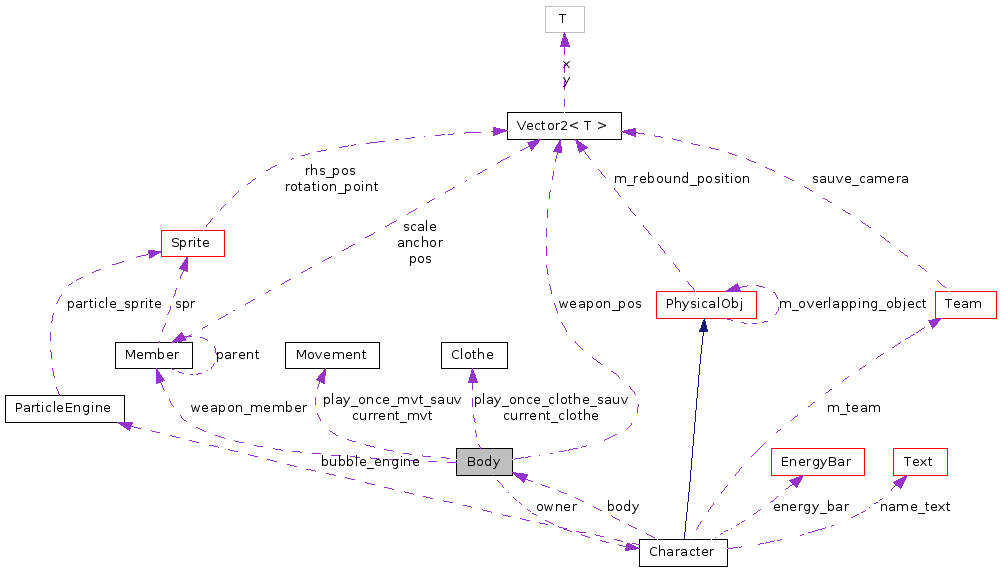
Collaboration diagram for Body:
Definition at line 47 of file body.h.
| enum Body::Direction_t |
Definition at line 50 of file body.h.
00051   {
00052     DIRECTION_LEFT = -1,
00053     DIRECTION_RIGHT = 1
00054   } Direction_t;
| Body::Body | ( | xmlpp::Element * | xml, | |
| Profile * | res | |||
| ) |
Definition at line 36 of file body.cpp.
00037 {
00038   need_rebuild = true;
00039   current_clothe = NULL;
00040   current_mvt = NULL;
00041   walk_events = 0;
00042   animation_number = 0;
00043   direction = DIRECTION_RIGHT;
00044   main_rotation_rad = 0;
00045
00046   // Load members
00047   xmlpp::Node::NodeList nodes = xml -> get_children("sprite");
00048   xmlpp::Node::NodeList::iterator it=nodes.begin();
00049
00050   while(it != nodes.end())
00051    {
00052     xmlpp::Element *elem = dynamic_cast<xmlpp::Element*> (*it);
00053     std::string name;
00054     XmlReader::ReadStringAttr( elem, "name", name);
00055
00056     Member* member = new Member(elem, res);
00057     if(members_lst.find(name) != members_lst.end())
00058       std::cerr << "Warning !! The member \""<< name << "\" is defined twice in the xml file" << std::endl;
00059     else
00060       members_lst[name] = member;
00061
00062     it++;
00063   }
00064
00065   // Add a special weapon member to the body
00066   weapon_member = new WeaponMember();
00067   members_lst["weapon"] = weapon_member;
00068
00069   // Load clothes
00070   xmlpp::Node::NodeList nodes2 = xml -> get_children("clothe");
00071   xmlpp::Node::NodeList::iterator it2=nodes2.begin();
00072
00073   while(it2 != nodes2.end())
00074   {
00075     xmlpp::Element *elem = dynamic_cast<xmlpp::Element*> (*it2);
00076     std::string name;
00077     XmlReader::ReadStringAttr( elem, "name", name);
00078
00079     Clothe* clothe = new Clothe(elem, members_lst);
00080     if (clothes_lst.find(name) != clothes_lst.end())
00081       std::cerr << "Warning !! The clothe \""<< name << "\" is defined twice in the xml file" << std::endl;
00082     else
00083       clothes_lst[name] = clothe;
00084
00085     it2++;
00086   }
00087
00088   // Load movements alias
00089   xmlpp::Node::NodeList nodes4 = xml -> get_children("alias");
00090   xmlpp::Node::NodeList::iterator it4=nodes4.begin();
00091   std::map<std::string, std::string> mvt_alias;
00092   while(it4 != nodes4.end())
00093    {
00094     xmlpp::Element *elem = dynamic_cast<xmlpp::Element*> (*it4);
00095     std::string mvt, corresp;
00096     XmlReader::ReadStringAttr( elem, "movement", mvt);
00097     XmlReader::ReadStringAttr( elem, "correspond_to", corresp);
00098     mvt_alias.insert(std::make_pair(mvt,corresp));
00099     it4++;
00100   }
00101
00102   // Load movements
00103   xmlpp::Node::NodeList nodes3 = xml -> get_children("movement");
00104   xmlpp::Node::NodeList::iterator it3=nodes3.begin();
00105
00106   while(it3 != nodes3.end())
00107   {
00108     xmlpp::Element *elem = dynamic_cast<xmlpp::Element*> (*it3);
00109     std::string name;
00110     XmlReader::ReadStringAttr( elem, "name", name);
00111     if(strncmp(name.c_str(),"animation", 9)==0)
00112       animation_number++;
00113
00114     Movement* mvt = new Movement(elem);
00115     if(mvt_lst.find(name) != mvt_lst.end())
00116       std::cerr << "Warning !! The movement \""<< name << "\" is defined twice in the xml file" << std::endl;
00117     else
00118       mvt_lst[name] = mvt;
00119
00120     for(std::map<std::string, std::string>::iterator it = mvt_alias.begin();
00121         it != mvt_alias.end();  ++it)
00122     if(it->second == name)
00123     {
00124       Movement* mvt = new Movement(elem);
00125       mvt->type = it->first;
00126       mvt_lst[it->first] = mvt;
00127     }
00128     it3++;
00129   }
00130 }
Here is the call graph for this function:
| Body::Body | ( | Body * | _body | ) |
Definition at line 132 of file body.cpp.
00133 {
00134   need_rebuild = true;
00135   current_clothe = NULL;
00136   current_mvt = NULL;
00137   walk_events = 0;
00138   animation_number = _body->animation_number;
00139   direction = DIRECTION_RIGHT;
00140   main_rotation_rad = 0;
00141
00142   // Add a special weapon member to the body
00143   weapon_member = new WeaponMember();
00144   members_lst["weapon"] = weapon_member;
00145
00146   // Make a copy of members
00147   std::map<std::string, Member*>::iterator it1 = _body->members_lst.begin();
00148   while(it1 != _body->members_lst.end())
00149   if(it1->second->name != "weapon")
00150   {
00151     std::pair<std::string,Member*> p;
00152     p.first = it1->first;
00153     p.second = new Member(it1->second);
00154     members_lst.insert(p);
00155     it1++;
00156   }
00157   else
00158     it1++;
00159
00160   // Make a copy of clothes
00161   std::map<std::string, Clothe*>::iterator it2 = _body->clothes_lst.begin();
00162   while(it2 != _body->clothes_lst.end())
00163   {
00164     std::pair<std::string,Clothe*> p;
00165     p.first = it2->first;
00166     p.second = new Clothe(it2->second, members_lst);
00167     clothes_lst.insert(p);
00168     it2++;
00169   }
00170
00171   // Movement are shared
00172   std::map<std::string, Movement*>::iterator it3 = _body->mvt_lst.begin();
00173   while(it3 != _body->mvt_lst.end())
00174   {
00175     std::pair<std::string,Movement*> p;
00176     p.first = it3->first;
00177     p.second = it3->second;
00178     mvt_lst.insert(p);
00179     it3++;
00180   }
00181 }
| Body::~Body | ( | ) |
Definition at line 183 of file body.cpp.
00184 {
00185   // Pointers inside those lists are freed from the body_list
00186   // Clean the members list
00187   std::map<std::string, Member*>::iterator it = members_lst.begin();
00188   while(it != members_lst.end())
00189   {
00190     delete it->second;
00191     it++;
00192   }
00193
00194   // Clean the clothes list
00195   std::map<std::string, Clothe*>::iterator it2 = clothes_lst.begin();
00196   while(it2 != clothes_lst.end())
00197   {
00198     delete it2->second;
00199     it2++;
00200   }
00201
00202   members_lst.clear();
00203   clothes_lst.clear();
00204   mvt_lst.clear();
00205 }
| void Body::AddChildMembers | ( | Member * | parent | ) | [private] |
Definition at line 375 of file body.cpp.
00376 {
00377   // Add child members of the parent member to the squeleton
00378   // and continue recursively with child members
00379   for(std::map<std::string, v_attached>::iterator child = parent->attached_members.begin();
00380       child != parent->attached_members.end();
00381       child++)
00382   {
00383     // Find if the current clothe uses this member:
00384     for(uint lay = 0; lay < current_clothe->layers.size(); lay++)
00385     {
00386       if(current_clothe->layers[lay]->type == child->first)
00387       {
00388         // This child member is attached to his parent
00389         junction body;
00390         body.member = current_clothe->layers[lay];
00391         body.parent = parent;
00392         squel_lst.push_back(body);
00393
00394         // continue recursively
00395         AddChildMembers(current_clothe->layers[lay]);
00396       }
00397     }
00398   }
00399 }
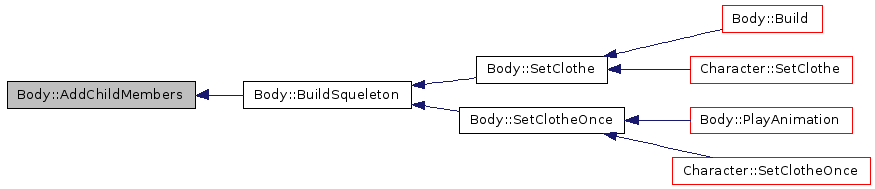
Here is the caller graph for this function:
Definition at line 213 of file body.cpp.
00214 {
00215   // Move each member following the movement description
00216   // We do it using the order of the squeleton, as the movement of each
00217   // member affect the child members as well
00218   std::vector<junction>::iterator member = squel_lst.begin();
00219   for(;member != squel_lst.end();
00220        member++)
00221   {
00222     assert( frame < mvt->frames.size() );
00223     if(mvt->frames[frame].find(member->member->type) != mvt->frames[frame].end())
00224     {
00225       // This member needs to be moved :
00226       member_mvt mb_mvt = mvt->frames[frame].find(member->member->type)->second;
00227       if(mb_mvt.follow_crosshair && ActiveCharacter().body == this && ActiveTeam().AccessWeapon().UseCrossHair())
00228       {
00229         // Use the movement of the crosshair
00230         double angle = owner->GetFiringAngle(); /* Get -2 * M_PI < angle =< 2 * M_PI*/
00231         if(angle < 0)
00232           angle += 2 * M_PI; // so now 0 < angle < 2 * M_PI;
00233         if(ActiveCharacter().GetDirection() == DIRECTION_LEFT)
00234           angle = M_PI - angle;
00235
00236         mb_mvt.SetAngle(mb_mvt.GetAngle() + angle);
00237       }
00238
00239       if(mb_mvt.follow_half_crosshair && ActiveCharacter().body == this && ActiveTeam().AccessWeapon().UseCrossHair())
00240       {
00241         // Use the movement of the crosshair
00242         double angle_rad = owner->GetFiringAngle(); // returns -180 < angle < 180
00243         if(ActiveCharacter().GetDirection() == DIRECTION_RIGHT)
00244           angle_rad /= 2; // -90 < angle < 90
00245         else
00246         if(angle_rad > M_PI_2)
00247           angle_rad = M_PI_2 - angle_rad / 2;//formerly in deg to 45 + (90 - angle) / 2;
00248         else
00249           angle_rad = -M_PI_2 - angle_rad / 2;//formerly in deg to -45 + (-90 - angle) / 2;
00250
00251
00252
00253         if(angle_rad < 0)
00254           angle_rad += 2 * M_PI; // so now 0 < angle < 2 * M_PI;
00255
00256         mb_mvt.SetAngle(mb_mvt.GetAngle() + angle_rad);
00257       }
00258
00259       if(mb_mvt.follow_speed)
00260       {
00261         // Use the movement of the character
00262         double angle_rad = (owner->GetSpeedAngle());
00263         if(angle_rad < 0)
00264           angle_rad += 2 * M_PI; // so now 0 < angle < 2 * M_PI;
00265         if(owner->GetDirection() == DIRECTION_LEFT)
00266           angle_rad = M_PI - angle_rad;
00267
00268         mb_mvt.SetAngle(mb_mvt.GetAngle() + angle_rad);
00269       }
00270
00271       if(mb_mvt.follow_direction)
00272       {
00273         // Use the direction of the character
00274         if(owner->GetDirection() == DIRECTION_LEFT)
00275           mb_mvt.SetAngle(mb_mvt.GetAngle() + M_PI);
00276       }
00277
00278
00279       member->member->ApplyMovement(mb_mvt, squel_lst);
00280     }
00281   }
00282 }
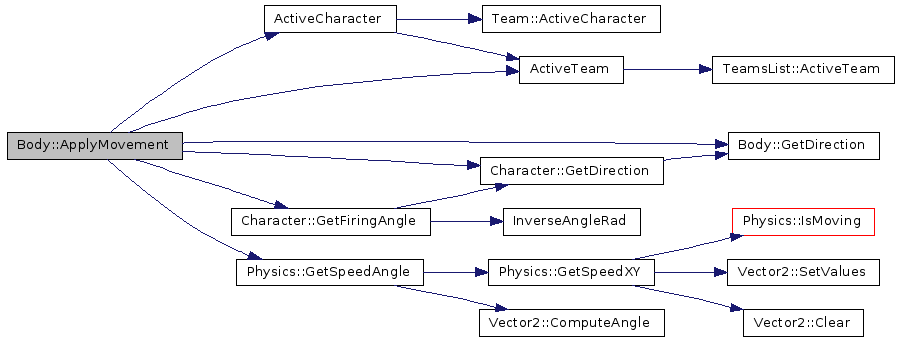
Here is the call graph for this function:
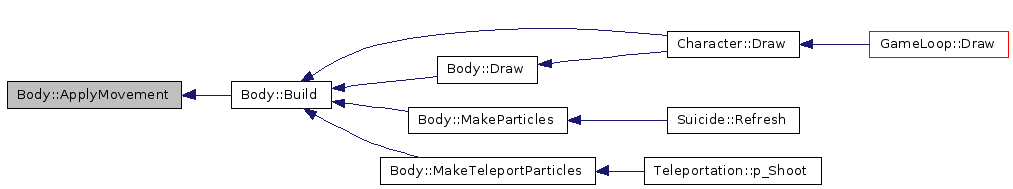
Here is the caller graph for this function:
| void Body::ApplySqueleton | ( | ) | [private] |
Definition at line 284 of file body.cpp.
00285 {
00286   // Move each member following the squeleton
00287   std::vector<junction>::iterator member = squel_lst.begin();
00288   // The first member is the body, we set it to pos:
00289   member->member->pos = Point2f(0,0);
00290   member->member->SetAngle(0);
00291   member++;
00292
00293   for(;member != squel_lst.end();
00294        member++)
00295   {
00296     // Place the other members depending of the parent member:
00297     member->member->ApplySqueleton(member->parent);
00298   }
00299 }
Here is the caller graph for this function:
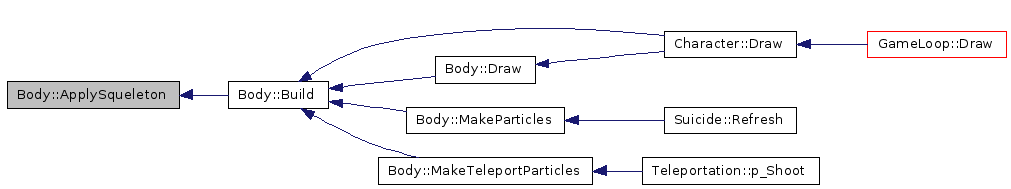
| void Body::Build | ( | ) |
Definition at line 301 of file body.cpp.
00302 {
00303   // Increase frame number if needed
00304   unsigned int last_frame = current_frame;
00305   if(walk_events > 0 || current_mvt->type!="walk")
00306   if(Time::GetInstance()->Read() > last_refresh + current_mvt->speed)
00307   {
00308     current_frame += (Time::GetInstance()->Read()-last_refresh) / current_mvt->speed;
00309     last_refresh += ((Time::GetInstance()->Read()-last_refresh) / current_mvt->speed) * current_mvt->speed;
00310
00311     if(current_frame >= current_mvt->frames.size())
00312     {
00313       if(play_once_clothe_sauv)
00314         SetClothe(play_once_clothe_sauv->name);
00315       if(play_once_mvt_sauv)
00316       {
00317         SetMovement(play_once_mvt_sauv->type);
00318         current_frame = play_once_frame_sauv;
00319       }
00320     }
00321     current_frame %= current_mvt->frames.size();
00322   }
00323
00324   need_rebuild |= (last_frame != current_frame);
00325   need_rebuild |= current_mvt->always_moving;
00326
00327   if(!need_rebuild)
00328     return;
00329
00330   ResetMovement();
00331   ApplySqueleton();
00332   ApplyMovement(current_mvt, current_frame);
00333
00334   // Rotate each sprite, because the next part need to know the height of the sprite
00335   // once he is rotated
00336   for(int layer=0;layer < (int)current_clothe->layers.size() ;layer++)
00337   if(current_clothe->layers[layer]->name != "weapon")
00338     current_clothe->layers[layer]->RotateSprite();
00339
00340   // Move the members to get the lowest member at the bottom of the skin rectangle
00341   member_mvt body_mvt;
00342   float y_max = 0;
00343   for(int lay=0;lay < (int)current_clothe->layers.size() ;lay++)
00344   if(current_clothe->layers[lay]->name != "weapon")
00345   {
00346     Member* member = current_clothe->layers[lay];
00347     if(member->pos.y + member->spr->GetHeightMax() + member->spr->GetRotationPoint().y > y_max
00348     && !member->go_through_ground)
00349       y_max = member->pos.y + member->spr->GetHeightMax() + member->spr->GetRotationPoint().y;
00350   }
00351   body_mvt.pos.y = (float)GetSize().y - y_max + current_mvt->test_bottom;
00352   body_mvt.pos.x = GetSize().x / 2.0 - squel_lst.front().member->spr->GetWidth() / 2.0;
00353   body_mvt.SetAngle(main_rotation_rad);
00354   squel_lst.front().member->ApplyMovement(body_mvt, squel_lst);
00355
00356   need_rebuild = false;
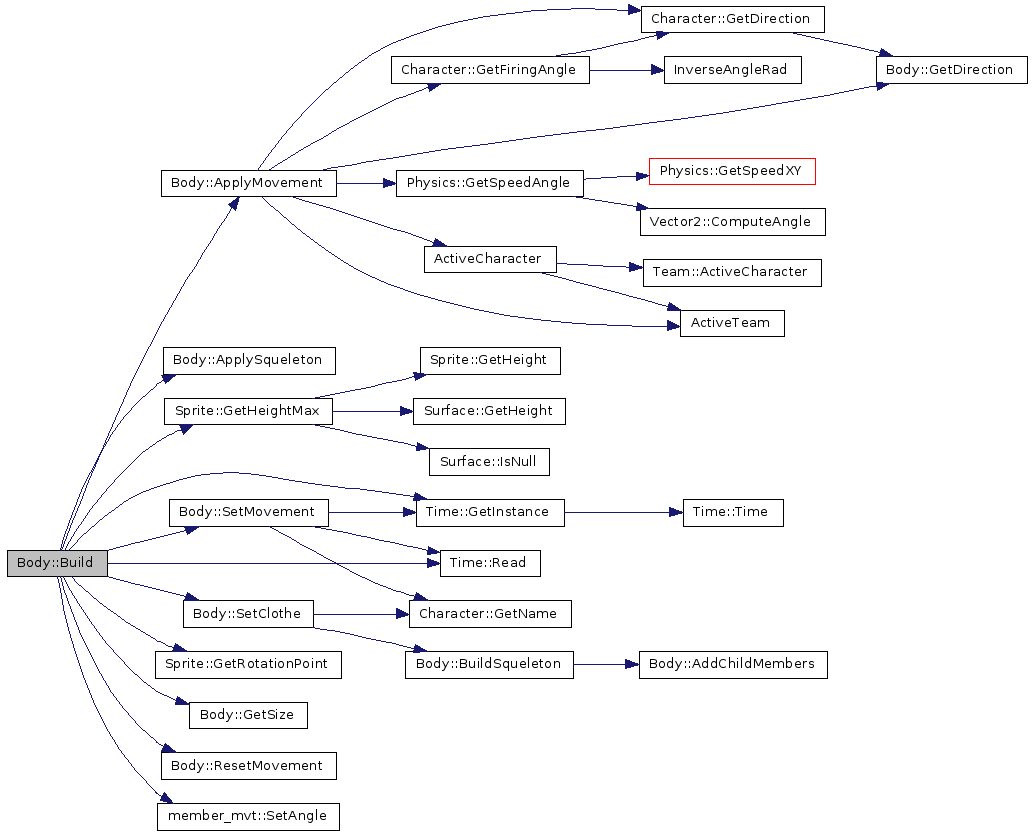
00357 }
Here is the call graph for this function:
Here is the caller graph for this function:
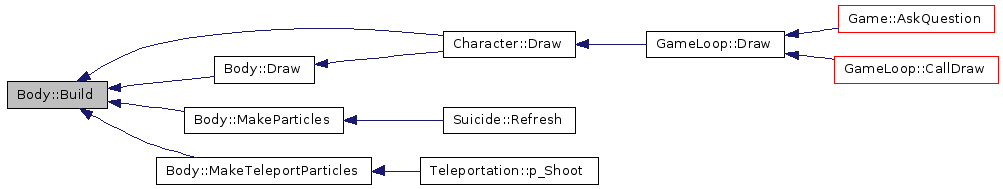
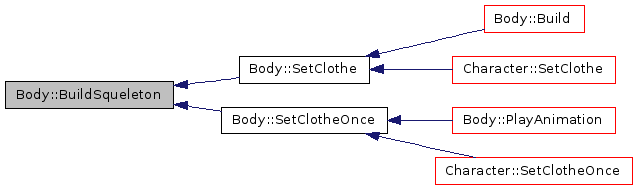
| void Body::BuildSqueleton | ( | ) | [private] |
Definition at line 401 of file body.cpp.
00402 {
00403   // Find each member used by the current clothe
00404   // and set the parent member of each member
00405   squel_lst.clear();
00406
00407   // Find the "body" member as its the top of the squeleton
00408   for(uint lay = 0; lay < current_clothe->layers.size(); lay++)
00409   if(current_clothe->layers[lay]->type == "body")
00410   {
00411     junction body;
00412     body.member = current_clothe->layers[lay];
00413     body.parent = NULL;
00414     squel_lst.push_back(body);
00415     break;
00416   }
00417
00418   if(squel_lst.size() == 0)
00419   {
00420     std::cerr << "Unable to find the \"body\" member in the current clothe" << std::endl;
00421     assert(false);
00422   }
00423
00424   AddChildMembers(squel_lst.front().member);
00425 }
Here is the call graph for this function:

Here is the caller graph for this function:
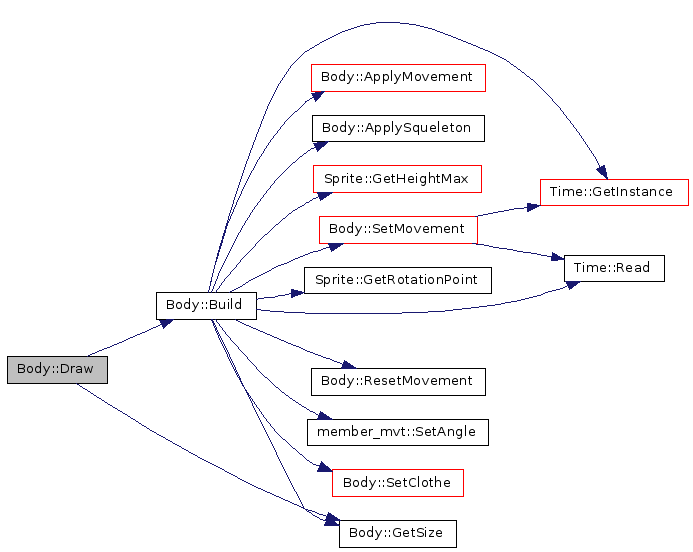
| void Body::Draw | ( | const Point2i & | pos | ) |
Definition at line 359 of file body.cpp.
00360 {
00361   Build();
00362
00363   // update the weapon position
00364   if(direction == DIRECTION_RIGHT)
00365     weapon_pos = Point2i((int)weapon_member->pos.x,(int)weapon_member->pos.y);
00366   else
00367     weapon_pos = Point2i(GetSize().x - (int)weapon_member->pos.x,(int)weapon_member->pos.y);
00368   weapon_pos += _pos;
00369
00370   // Finally draw each layer one by one
00371   for(int layer=0;layer < (int)current_clothe->layers.size() ;layer++)
00372     current_clothe->layers[layer]->Draw(_pos, _pos.x + GetSize().x/2, int(direction));
00373 }
Here is the call graph for this function:
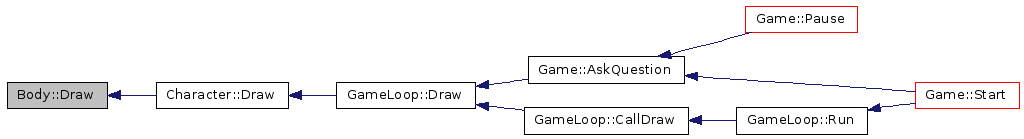
Here is the caller graph for this function:
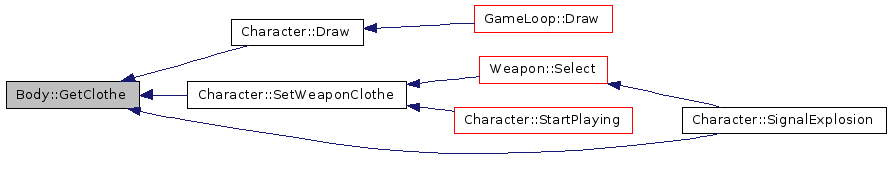
| const std::string & Body::GetClothe | ( | ) |
Definition at line 632 of file body.cpp.
00632 { return current_clothe->name; }
Here is the caller graph for this function:
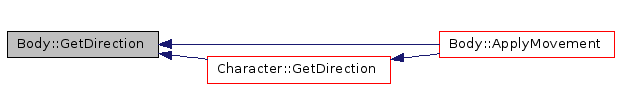
| const Body::Direction_t & Body::GetDirection | ( | ) | const |
| uint Body::GetFrame | ( | ) | [inline] |
Definition at line 122 of file body.h.
00122 { return current_frame; };
Here is the caller graph for this function:
| uint Body::GetFrameCount | ( | ) |
Definition at line 588 of file body.cpp.
00589 {
00590   return current_mvt->frames.size();
00591 }
Here is the caller graph for this function:

| const Point2i & Body::GetHandPosition | ( | ) | const |
Definition at line 554 of file body.cpp.
00555 {
00556   return weapon_pos;
00557 }
Here is the caller graph for this function:
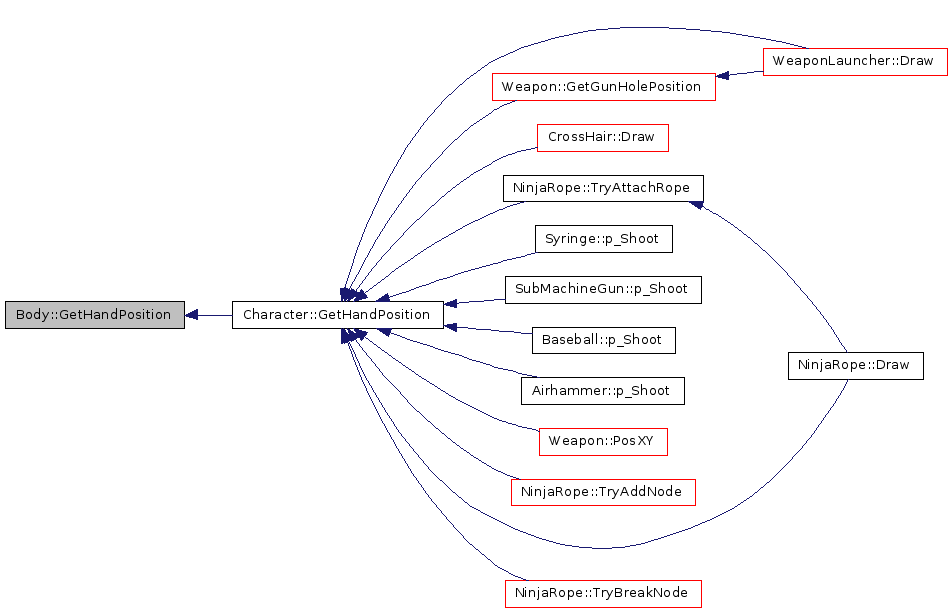
| const std::string & Body::GetMovement | ( | ) |
Definition at line 631 of file body.cpp.
00631 { return current_mvt->type; }
Here is the caller graph for this function:
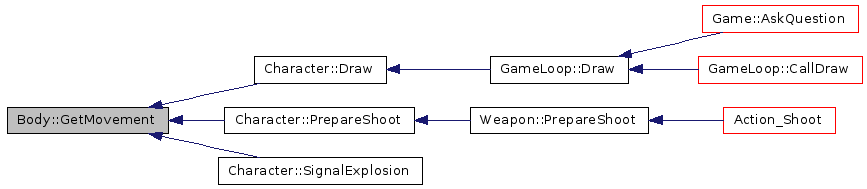
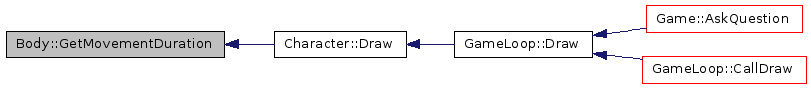
| uint Body::GetMovementDuration | ( | ) |
Definition at line 583 of file body.cpp.
00584 {
00585   return current_mvt->frames.size() * current_mvt->speed;
00586 }
Here is the caller graph for this function:
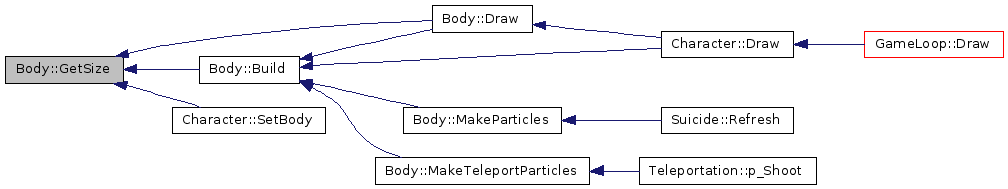
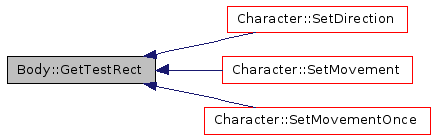
| Point2i Body::GetSize | ( | ) | [inline] |
Definition at line 528 of file body.cpp.
00529 {
00530   if(direction == DIRECTION_RIGHT)
00531   {
00532     l = current_mvt->test_left;
00533     r = current_mvt->test_right;
00534   }
00535   else
00536   {
00537     r = current_mvt->test_left;
00538     l = current_mvt->test_right;
00539   }
00540   t = current_mvt->test_top;
00541   b = current_mvt->test_bottom;
00542 }
Here is the caller graph for this function:
| bool Body::IsWalking | ( | ) | [inline] |
Definition at line 128 of file body.h.
00128 { return walk_events > 0 && current_mvt->type == "walk";};
Here is the caller graph for this function:
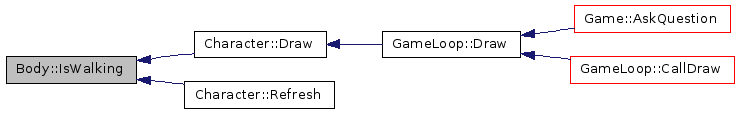
| void Body::MakeParticles | ( | const Point2i & | pos | ) |
Definition at line 600 of file body.cpp.
00601 {
00602   Build();
00603
00604   for(int layer=0;layer < (int)current_clothe->layers.size() ;layer++)
00605   if(current_clothe->layers[layer]->type != "weapon")
00606     ParticleEngine::AddNow(new BodyMemberParticle(current_clothe->layers[layer]->spr,
00607                                                   current_clothe->layers[layer]->GetPos()+pos));
00608 }
Here is the call graph for this function:
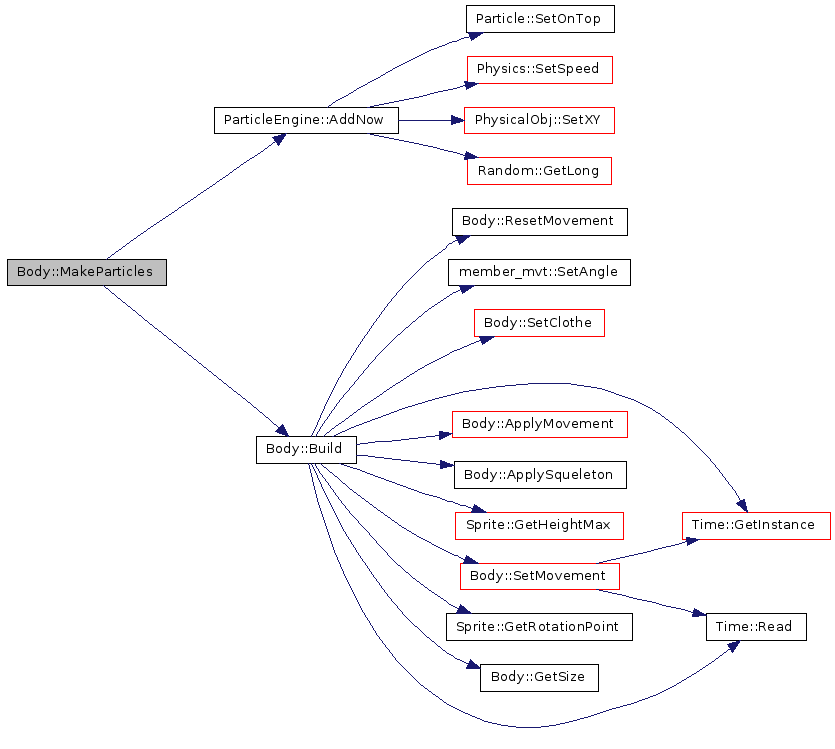
Here is the caller graph for this function:
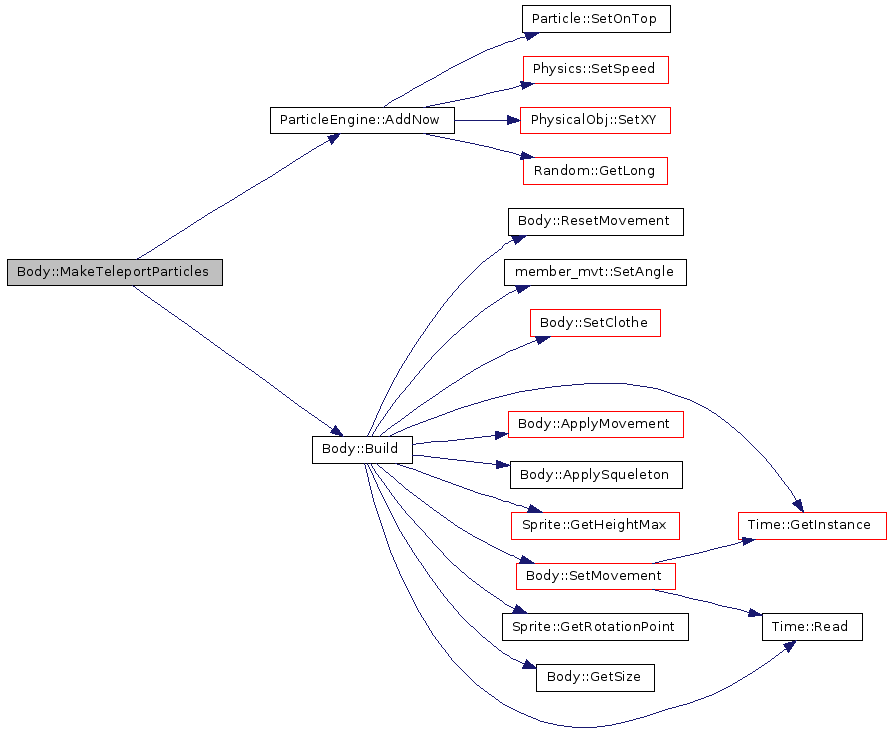
Definition at line 610 of file body.cpp.
00611 {
00612   Build();
00613
00614   for(int layer=0;layer < (int)current_clothe->layers.size() ;layer++)
00615   if(current_clothe->layers[layer]->type != "weapon")
00616   {
00617     ParticleEngine::AddNow(new TeleportMemberParticle(current_clothe->layers[layer]->spr,
00618                                                       current_clothe->layers[layer]->GetPos()+pos,
00619                                                       current_clothe->layers[layer]->GetPos()+dst,
00620                                                       int(direction)));
00621   }
00622 }
Here is the call graph for this function:
Here is the caller graph for this function:

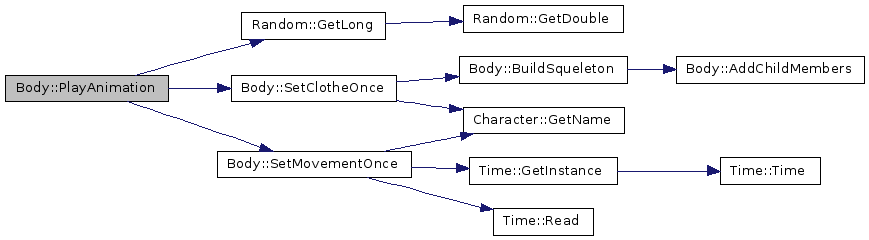
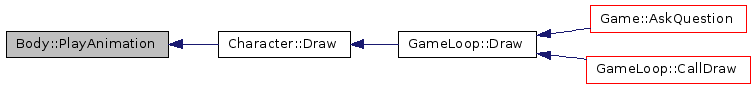
| void Body::PlayAnimation | ( | ) |
Definition at line 472 of file body.cpp.
00473 {
00474   std::ostringstream name;
00475   name << "animation" << randomObj.GetLong(0, animation_number - 1);
00476   SetClotheOnce(name.str());
00477   SetMovementOnce(name.str());
00478 }
Here is the call graph for this function:
Here is the caller graph for this function:
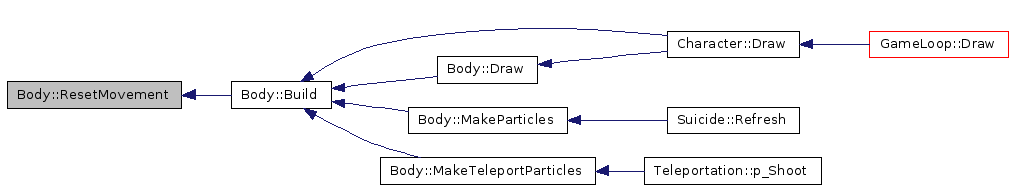
| void Body::ResetMovement | ( | ) | [private] |
Definition at line 207 of file body.cpp.
00208 {
00209   for(int layer=0;layer < (int)current_clothe->layers.size() ;layer++)
00210     current_clothe->layers[layer]->ResetMovement();
00211 }
Here is the caller graph for this function:
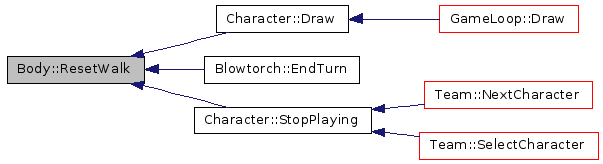
| void Body::ResetWalk | ( | ) |
Definition at line 578 of file body.cpp.
00579 {
00580   walk_events = 0;
00581 }
Here is the caller graph for this function:
| void Body::SetClothe | ( | std::string | name | ) |
Definition at line 427 of file body.cpp.
00428 {
00429   MSG_DEBUG("body", " %s use clothe %s", owner->GetName().c_str(), name.c_str());
00430   if(current_clothe && current_clothe->name == name) return;
00431
00432   if(clothes_lst.find(name) != clothes_lst.end())
00433   {
00434     current_clothe = clothes_lst.find(name)->second;
00435     BuildSqueleton();
00436     main_rotation_rad = 0;
00437     need_rebuild = true;
00438   }
00439   else
00440     MSG_DEBUG("body","Clothe not found");
00441
00442
00443   play_once_clothe_sauv = NULL;
00444
00445   assert(current_clothe != NULL);
00446 }
Here is the call graph for this function:
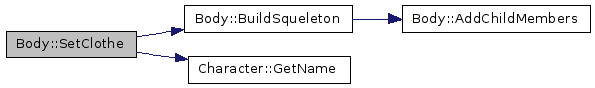
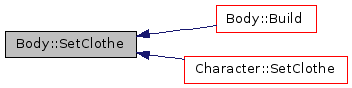
Here is the caller graph for this function:
| void Body::SetClotheOnce | ( | std::string | name | ) |
Definition at line 480 of file body.cpp.
00481 {
00482   MSG_DEBUG("body", " %s use clothe %s once", owner->GetName().c_str(), name.c_str());
00483   if(current_clothe && current_clothe->name == name) return;
00484
00485   if(clothes_lst.find(name) != clothes_lst.end())
00486   {
00487     if(!play_once_clothe_sauv)
00488       play_once_clothe_sauv = current_clothe;
00489     current_clothe = clothes_lst.find(name)->second;
00490     BuildSqueleton();
00491     main_rotation_rad = 0;
00492     need_rebuild = true;
00493   }
00494   else
00495     MSG_DEBUG("body","Clothe not found");
00496
00497   assert(current_clothe != NULL);
00498 }
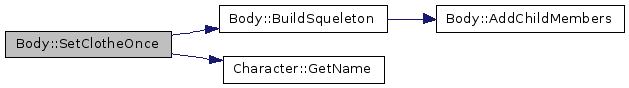
Here is the call graph for this function:
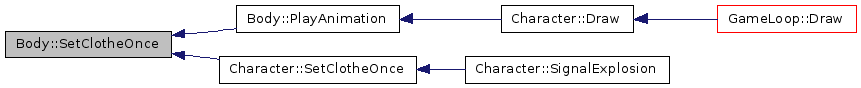
Here is the caller graph for this function:
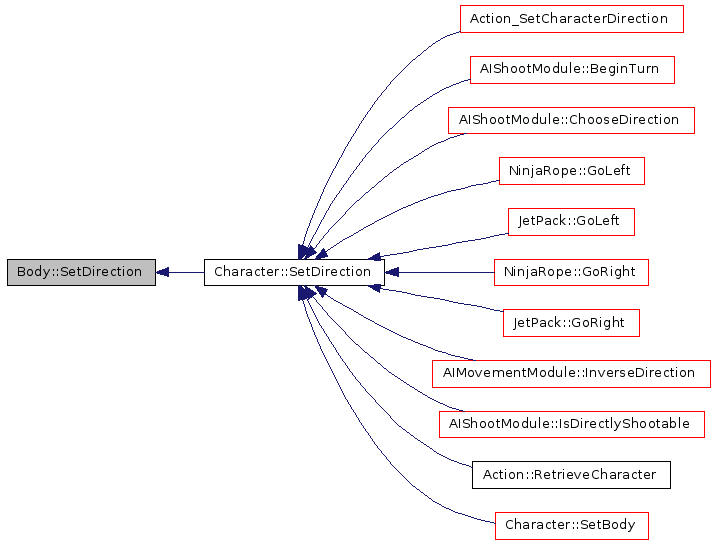
| void Body::SetDirection | ( | Body::Direction_t | dir | ) |
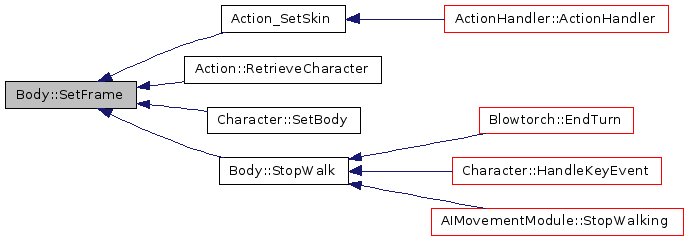
| void Body::SetFrame | ( | uint | no | ) |
Definition at line 593 of file body.cpp.
00594 {
00595   assert(no < current_mvt->frames.size());
00596   current_frame = no;
00597   need_rebuild = true;
00598 }
Here is the caller graph for this function:
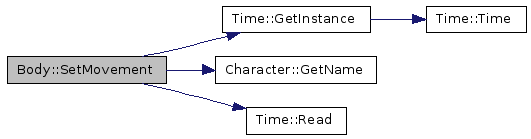
| void Body::SetMovement | ( | std::string | name | ) |
Definition at line 448 of file body.cpp.
00449 {
00450   MSG_DEBUG("body", " %s use movement %s", owner->GetName().c_str(), name.c_str());
00451   if(current_mvt && current_mvt->type == name) return;
00452
00453   // Dirty trick to get the "black" movement to be played fully
00454   if(current_clothe && current_clothe->name == "black") return;
00455
00456   if(mvt_lst.find(name) != mvt_lst.end())
00457   {
00458     current_mvt = mvt_lst.find(name)->second;
00459     current_frame = 0;
00460     last_refresh = Time::GetInstance()->Read();
00461     main_rotation_rad = 0;
00462     need_rebuild = true;
00463   }
00464   else
00465     MSG_DEBUG("body","Movement not found");
00466
00467   play_once_mvt_sauv = NULL;
00468
00469   assert(current_mvt != NULL);
00470 }
Here is the call graph for this function:
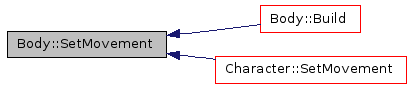
Here is the caller graph for this function:
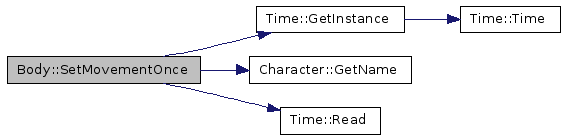
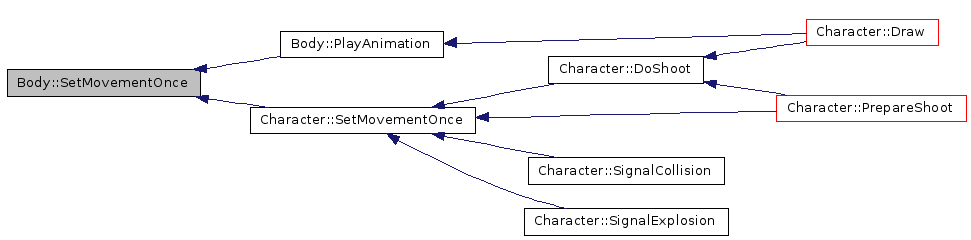
| void Body::SetMovementOnce | ( | std::string | name | ) |
Definition at line 500 of file body.cpp.
00501 {
00502   MSG_DEBUG("body", " %s use movement %s once", owner->GetName().c_str(), name.c_str());
00503   if(current_mvt && current_mvt->type == name) return;
00504
00505   // Dirty trick to get the "black" movement to be played fully
00506   if(current_clothe && current_clothe->name == "black"  && name != "black") return;
00507
00508   if(mvt_lst.find(name) != mvt_lst.end())
00509   {
00510     if(!play_once_mvt_sauv)
00511     {
00512       play_once_mvt_sauv = current_mvt;
00513       play_once_frame_sauv = current_frame;
00514     }
00515
00516     current_mvt = mvt_lst.find(name)->second;
00517     current_frame = 0;
00518     last_refresh = Time::GetInstance()->Read();
00519     main_rotation_rad = 0;
00520     need_rebuild = true;
00521   }
00522   else
00523     MSG_DEBUG("body","Movement not found");
00524
00525   assert(current_mvt != NULL);
00526 }
Here is the call graph for this function:
Here is the caller graph for this function:
| void Body::SetOwner | ( | const Character * | belonger | ) | [inline] |
| void Body::SetRotation | ( | double | angle | ) |
Definition at line 624 of file body.cpp.
00625 {
00626   MSG_DEBUG("body", "%s -> new angle: %i", owner->GetName().c_str(), angle);
00627   main_rotation_rad = angle;
00628   need_rebuild = true;
00629 }
Here is the call graph for this function:
Here is the caller graph for this function:
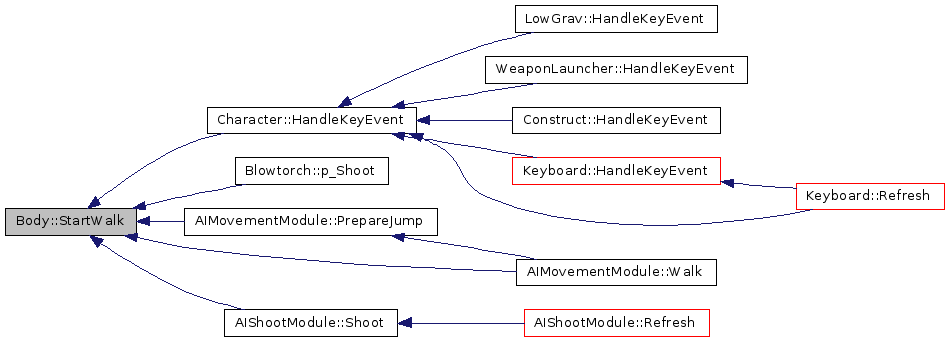
| void Body::StartWalk | ( | ) |
Definition at line 559 of file body.cpp.
00560 {
00561   // walk events happens when the player hits the left/right key
00562   // counting how much they are pressed allow to get skin walking
00563   // if the key was hit while the character was jumping or using an other
00564   // animation than the walk animation
00565   walk_events++;
00566   if(walk_events == 1)
00567     last_refresh = Time::GetInstance()->Read();
00568 }
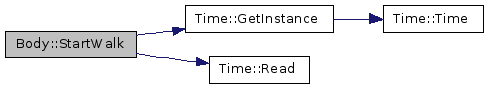
Here is the call graph for this function:
Here is the caller graph for this function:
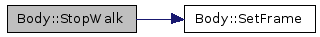
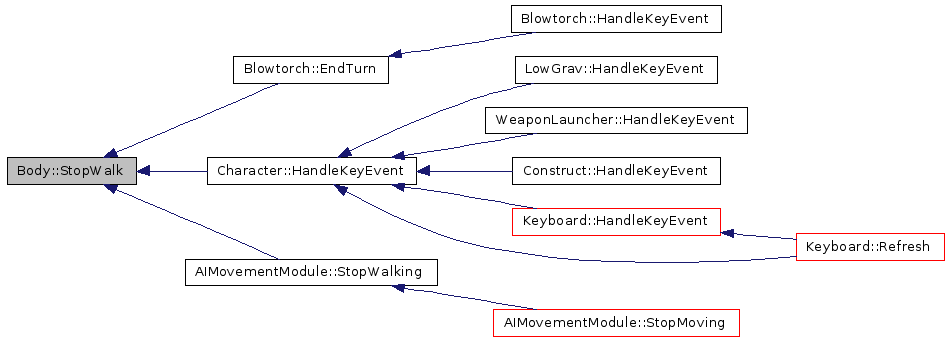
| void Body::StopWalk | ( | ) |
Definition at line 570 of file body.cpp.
00571 {
00572   if(walk_events > 0)
00573     walk_events--;
00574   if(current_mvt->type == "walk")
00575     SetFrame(0);
00576 }
Here is the call graph for this function:
Here is the caller graph for this function:
int Body::animation_number [private] |
std::map<std::string, Clothe*> Body::clothes_lst [private] |
Clothe* Body::current_clothe [private] |
uint Body::current_frame [private] |
Movement* Body::current_mvt [private] |
Body::Direction_t Body::direction [private] |
uint Body::last_refresh [private] |
double Body::main_rotation_rad [private] |
std::map<std::string, Member*> Body::members_lst [private] |
std::map<std::string, Movement*> Body::mvt_lst [private] |
bool Body::need_rebuild [private] |
const Character* Body::owner [private] |
Clothe* Body::play_once_clothe_sauv [private] |
uint Body::play_once_frame_sauv [private] |
Movement* Body::play_once_mvt_sauv [private] |
std::vector<junction> Body::squel_lst [private] |
int Body::walk_events [private] |
Member* Body::weapon_member [private] |
Point2i Body::weapon_pos [private] |
 1.4.7